Inertial Navigation Basics: Why the IMU Is the Heart of Your Navigation System
What an IMU does, why its errors grow with time, what to look for when selecting one — and why calibration quality decides everything.
ATEŞ Labs Engineering Blog · September 2026 · 8 min read
Fundamentals
What Is Inertial Navigation?
Inertial navigation is the art of knowing where you are without asking anyone. An Inertial Measurement Unit (IMU) — three gyroscopes and three accelerometers — measures angular rate and specific force. By integrating these measurements over time, an Inertial Navigation System (INS) computes attitude, velocity and position entirely on its own: no satellites, no radio beacons, no external references.
That self-reliance is exactly why inertial navigation matters more than ever. GNSS signals are weak, easily jammed and increasingly spoofed. In a contested environment, your IMU is the one sensor that cannot be denied.
Fully autonomous — immune to jamming and spoofing
High-rate attitude, velocity and position output
The core of every GNSS-denied navigation solution
The Physics
The Catch: Errors Grow With Time
The strength of inertial navigation — integration — is also its weakness. Every sensor error, however small, is integrated right along with the signal. Navigation errors don't stay constant; they grow.
Error source
Position error growth
What it means
Gyroscope bias
∝ t³
Tilts the attitude estimate, misprojects gravity, then integrates twice more — dominates INS grade.
Accelerometer bias
½·b·t²
A 1 mg bias means ~18 m of position error after just 60 seconds.
ARW / VRW (noise)
∝ √t
Sets the floor on performance even with perfect calibration.
Bias instability
slow wander
How far the bias drifts over minutes and hours — the limit of what estimation can remove.
Scale factor & misalignment
scales with dynamics
The harder you maneuver, the more they hurt.
The takeaway: an unaided INS is a clock that is always running down. The question is never whether errors grow — it's how fast, and whether that rate is acceptable for your mission duration and accuracy requirement.
Selection Guide
Choosing an IMU: What Actually Matters
Datasheets are full of numbers; only a few of them decide whether your system works.
1
Gyro bias instability & ARW
These two numbers determine free-inertial drift more than any others. Consumer MEMS: tens of °/h. Tactical: 0.5–10 °/h. Navigation grade: below 0.01 °/h. Match the grade to your GNSS-denied endurance — not to the best case.
2
Accelerometer bias & VRW
Critical for velocity accuracy and alignment: a 1 mg bias limits initial leveling to ~1 mrad of tilt error.
3
Behavior over environment
Bias over the full temperature range, turn-on repeatability, vibration rectification (VRE) and shock survivability matter more in the field than headline noise figures.
4
Bandwidth & output rate
High-dynamic platforms need enough sensor bandwidth to capture the motion, and deterministic low-latency output for the control loop.
5
SWaP-C
The best IMU is the lightest, cheapest one that still meets your drift budget — with margin.
6
Aiding strategy
No IMU flies alone forever. How gracefully the fusion degrades when GNSS, odometry or other aiding disappears is a system-level property worth evaluating as carefully as the sensor.
Why Calibration Decides
Calibrated Across the Full Temperature Range
Two IMUs built from the same sensors can perform worlds apart — the difference is calibration. At ATEŞ Labs, every aSense unit goes through a custom in-house calibration procedure covering the full operational temperature range, not just room temperature:
Thermal-chamber and rate-table characterization across the entire operating envelope
Per-unit compensation of bias, scale factor and axis misalignment as functions of temperature
Verified turn-on to turn-on repeatability — the spec you actually get in the field
A datasheet quotes numbers; calibration is what makes a unit meet them on a vibrating airframe at −40 °C.
Talk to ATEŞ Labs
We design and build the aSense family of tactical-grade IMUs and GNSS/INS systems for resilient navigation in GNSS-denied environments. If you're sizing an inertial solution for your platform, we'd be glad to help you work through the error budget and find the right fit.
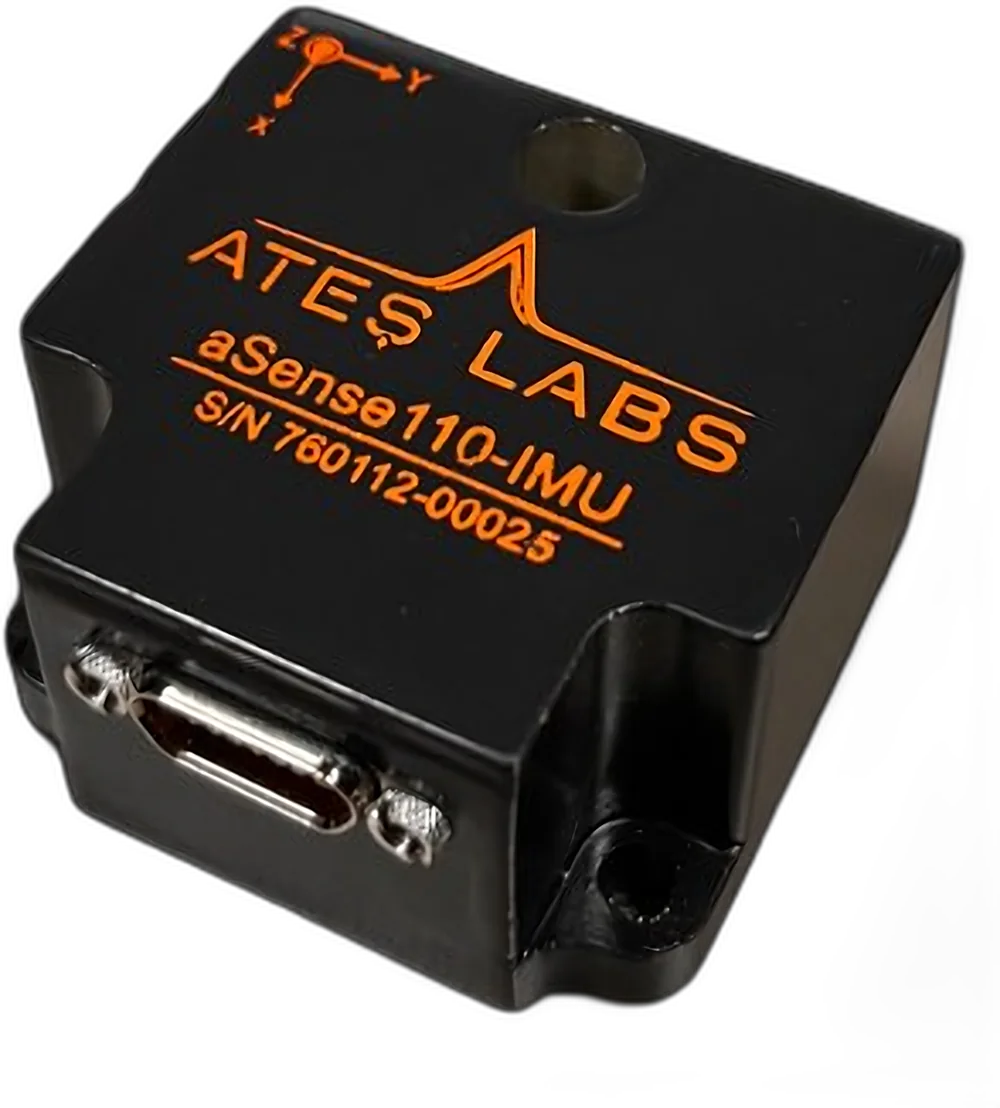 aSense110-IMU
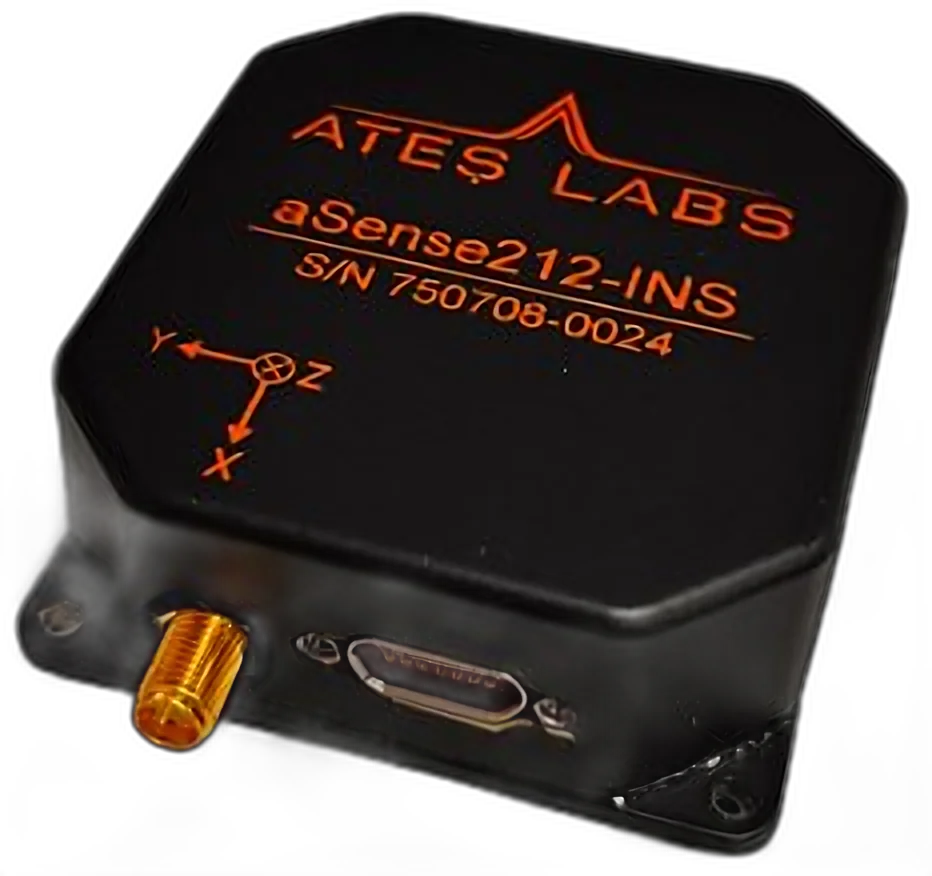 aSense210-INS
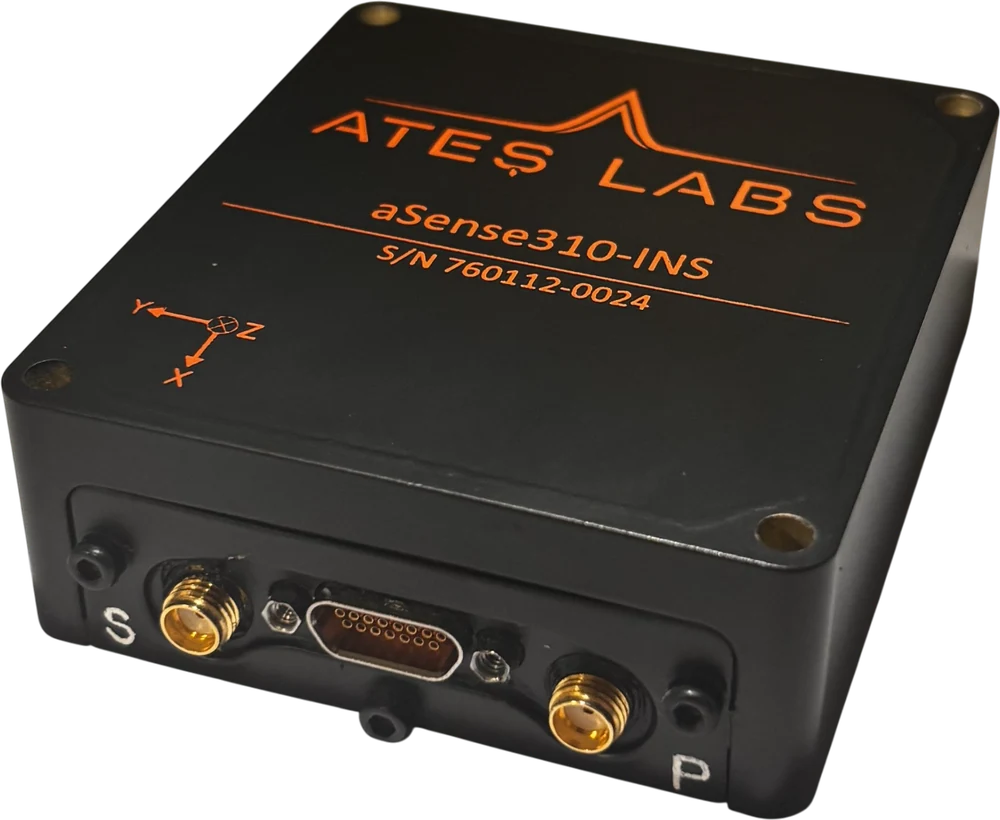 aSense310-INS
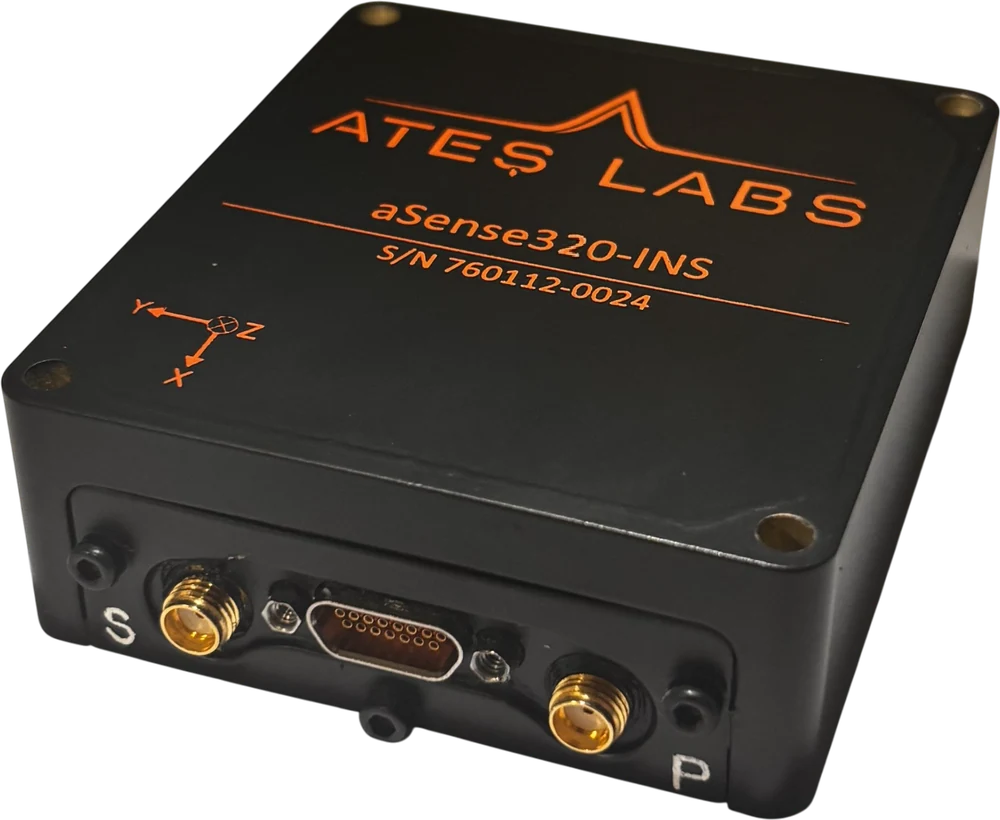 aSense320-INS
 GNSS-Denied Solution
Explore Navigation →
 SEZEN — Marine
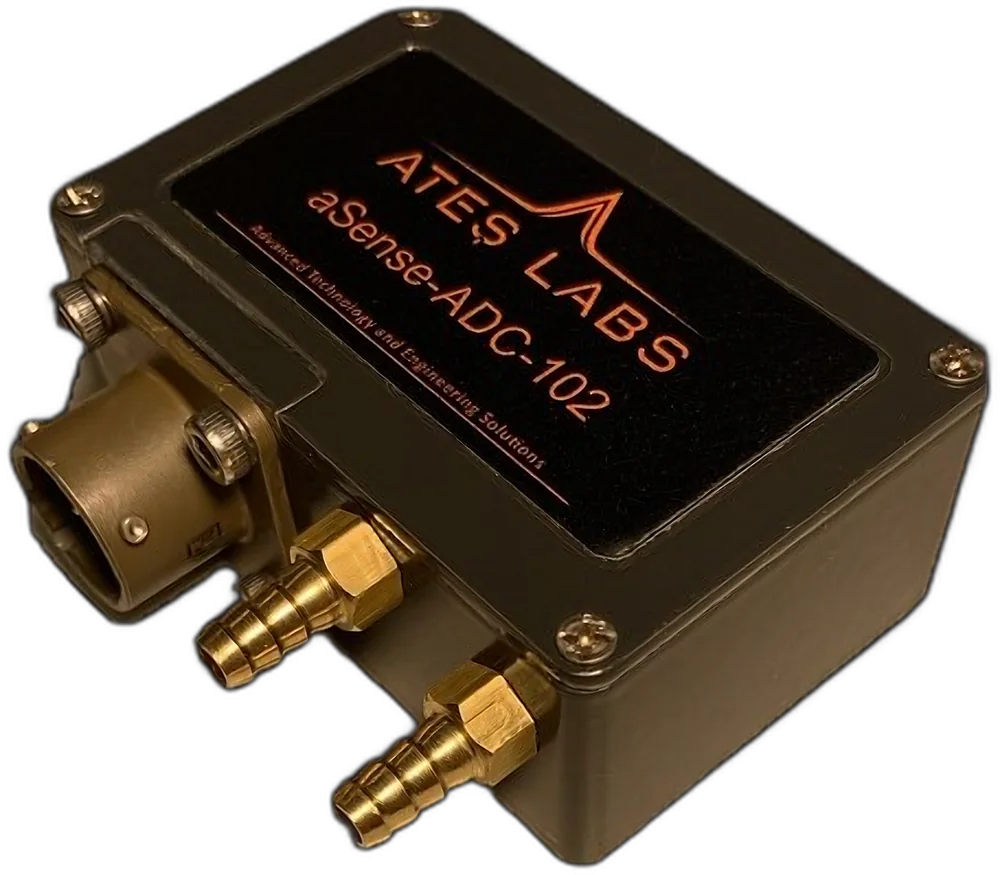 aSense ADC-TRD-102
 aSense ADC-TRD-106
Explore Air Data →
 aSIU-200
 HILS-200
 Power Electronics
Explore Electronic Design →